Real-time nowcasting: right-truncation vs the reporting triangle
In real time the most recent days of a surveillance series are incomplete. A case with reference day
This package corrects right-truncation two ways, and this tutorial fits and compares both on the same simulated data. RightTruncate is the marginal correction. It keeps only each reference day's observed-so-far total and scales the expected count by the reporting-delay CDF, the EpiNow2-style CDF-scaling nowcast. ReportTriangle is the joint correction. It keeps the full reference-day × reporting-delay triangle and scores it cell by cell, the epinowcast-style nowcast. The two share one reporting-delay kernel, so the triangle's observed row-sums are exactly the observed-so-far totals the marginal correction conditions on. Both leave the renewal infection process and its latent
The two corrections
The infection pipeline produces
Summing the joint model's observed cells over
The renewal model
Both corrections wrap the same composed renewal model as the renewal tutorial, an autoregressive Renewal infection process observed with a NegativeBinomialError.
using ComposableTuringIDModels, Distributions, Random, Turing, Mooncake
using ADTypes: AutoMooncake
using CSV, DataFrames
Random.seed!(20240625)

adt = AutoMooncake(; config = nothing)

latent = AR(
    damp = [truncated(Normal(0.8, 0.05), 0, 1)],
    init = [Normal(0.0, 0.25)],
    ϵ_t = HierarchicalNormal(std = HalfNormal(0.1)))
renewal = Renewal(; generation_time = Gamma(1.4, 1 / 0.38),
    rt = latent, initialisation = Normal(log(1.0), 1.0))
error = NegativeBinomialError(cluster_factor = HalfNormal(0.1))
Simulate a reporting triangle
We take the fully-reported Italy confirmed-case series as the eventual totals, split each day's total across reporting delays with the delay PMF, then mask the cells not yet reported at ReportingPMF discretises the reporting delay with the same CensoredDistributions.jl path the rest of the package uses.
datapath = joinpath(pkgdir(ComposableTuringIDModels),
    "docs", "src", "tutorials", "data", "italy_data.csv")
italy = CSV.read(datapath, DataFrame)
n = 45
eventual = italy.confirm[1:n]                 # eventual (complete) totals

reporting_delay = LogNormal(1.6, 0.5)         # mean ≈ 5.6 days
delay_pmf = ReportingPMF(reporting_delay; D = 10)
pmf = delay_pmf.pmf                            # delays 0 … Dmax
Dmax = length(pmf) - 1
Split each reference day's eventual total across delays with a multinomial draw, then keep only the cells reported by
full_triangle = reduce(vcat,
    (permutedims(rand(Multinomial(eventual[t], pmf))) for t in 1:n))
mask = [t + d <= n for t in 1:n, d in 0:Dmax]
reported_triangle = full_triangle .* mask
observed_so_far = vec(sum(reported_triangle, dims = 2))
(complete_tail = eventual[(end - 4):end],
    truncated_tail = observed_so_far[(end - 4):end])
(complete_tail = [4782, 4668, 4585, 4805, 4316], truncated_tail = [2245, 1249, 432, 58, 0])The recent days are visibly thinned, the most recent day showing only a fraction of its eventual count.
Visualise the data
The reporting triangle is the native data object. Plotting it with AlgebraOfGraphics, the not-yet-reported cells blanked, shows the staircase of missing counts in the recent corner.
using AlgebraOfGraphics, CairoMakie, DataFrames

tri_df = DataFrame(
    reference = repeat(1:n, outer = Dmax + 1),
    delay = repeat(0:Dmax, inner = n),
    count = vec(full_triangle),
    reported = vec(mask))
tri_df.shown = ifelse.(tri_df.reported, Float64.(tri_df.count), NaN)

draw(data(tri_df) *
     mapping(:reference, :delay, :shown => "Reported cases") * visual(Heatmap);
    axis = (xlabel = "Reference day", ylabel = "Reporting delay (days)"))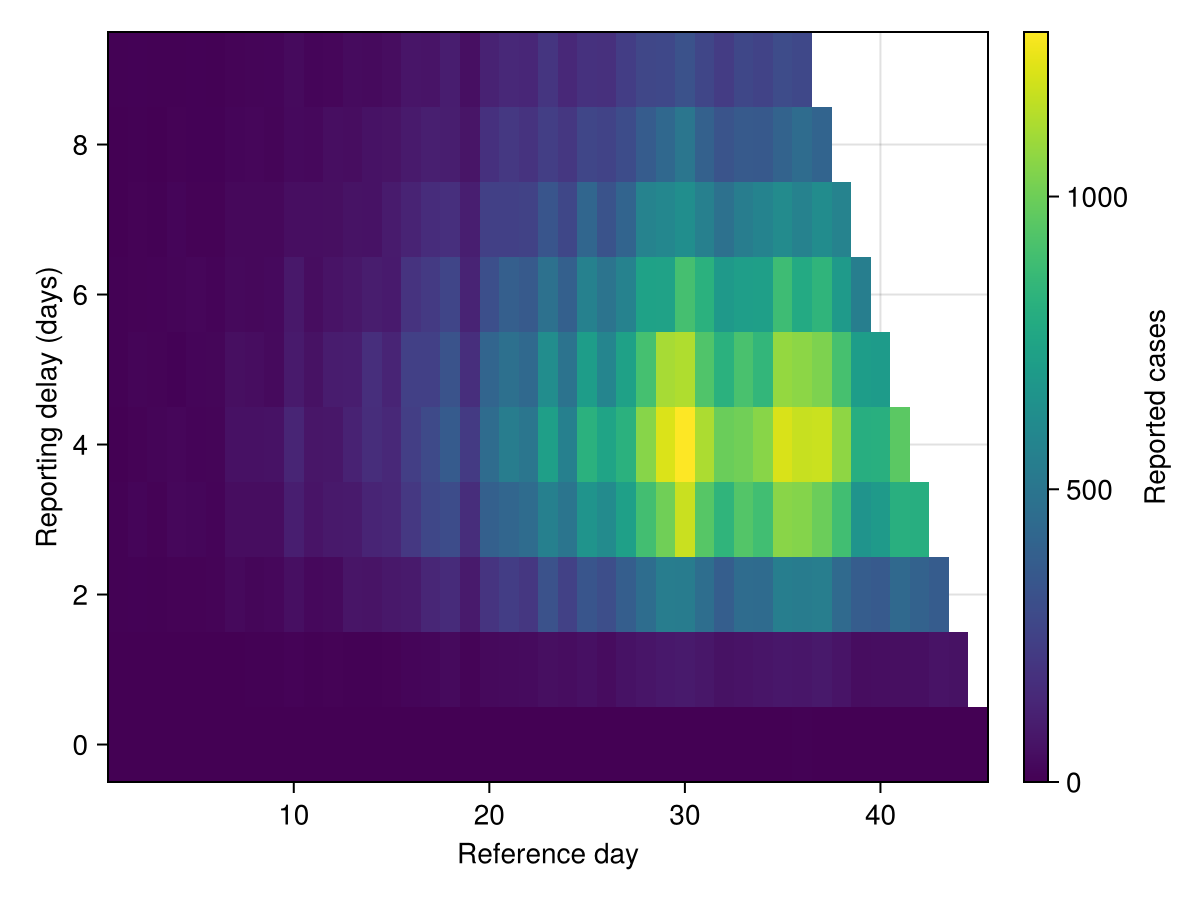
The same truncation reads as a shortfall in the tail when the observed-so-far row-sums are drawn against the eventual totals.
comp_df = DataFrame(
    reference = repeat(1:n, 2),
    count = vcat(eventual, observed_so_far),
    series = repeat(["eventual total", "observed so far"], inner = n))

draw(data(comp_df) * mapping(:reference, :count, color = :series) *
     visual(Lines); axis = (xlabel = "Reference day", ylabel = "Cases"))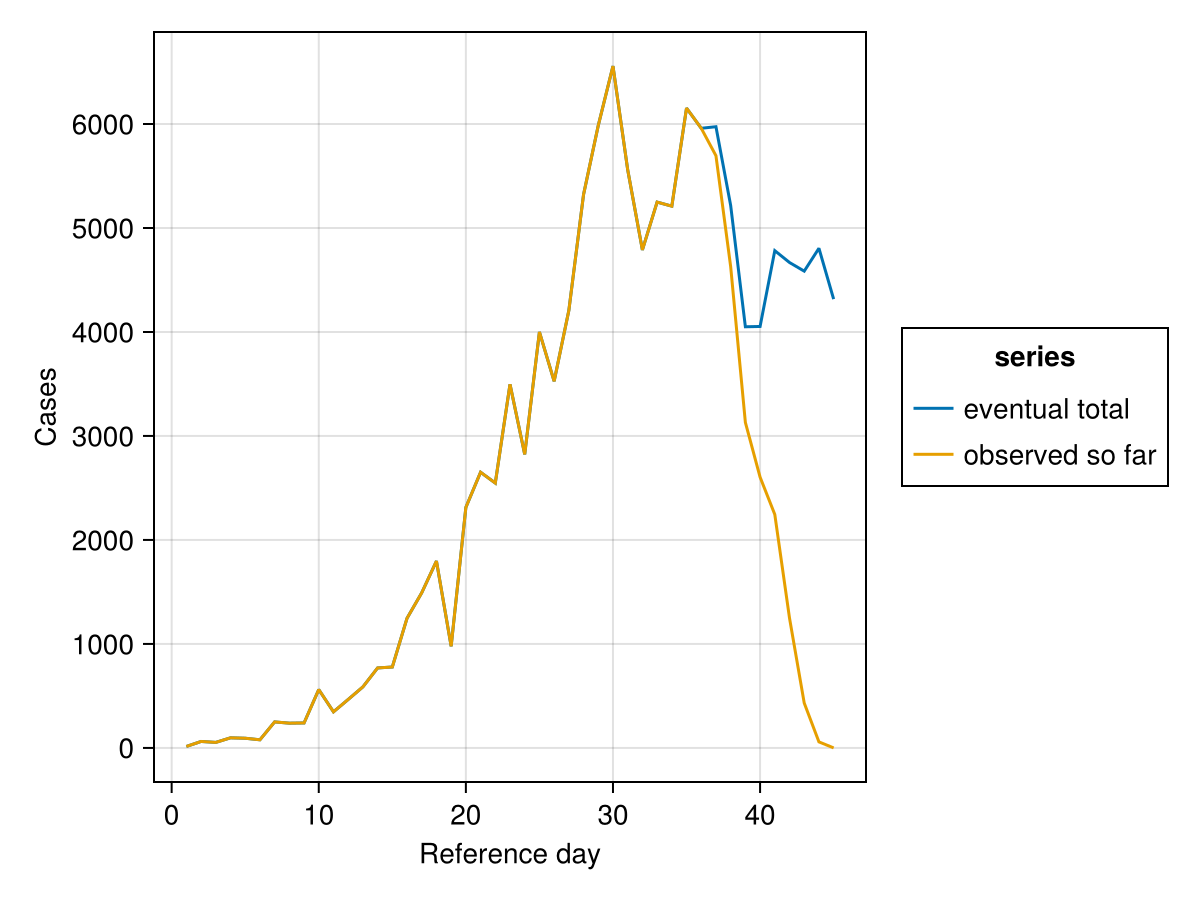
Three fits
We fit the plain renewal model three ways with NUTS, drawing two chains with 1000 warmup iterations each so the cross-chain RightTruncate applies the marginal correction to the same observed-so-far totals. ReportTriangle applies the joint correction to the reporting triangle, built through the shared define_y_t hook.
A fourth fit takes the plain model to the complete (untruncated) series, what the analyst would eventually see, as a reference.
The corrections differ from the plain model only in their observation model, so each is derived from it with Accessors.@set rather than rebuilt.
using Accessors

naive_model = IDModel(renewal, error)
rt_obs = RightTruncate(error, ReportingCDF(reporting_delay; D = 10))
rt_model = @set naive_model.observation_model = rt_obs
tri_obs = ReportTriangle(error, delay_pmf)
tri_model = @set naive_model.observation_model = tri_obs
IDModel
├─ infection: Renewal
│ └─ rt: AR
│ └─ ϵ_t: HierarchicalNormal
└─ observation: ReportTriangle
├─ error: NegativeBinomialError
└─ delay: ReportingPMFA fit is a model and the data it is scored against. The four are a table of pairs, so the sampler call is written once.
specs = (
    naive = (model = naive_model, data = observed_so_far),
    right_truncate = (model = rt_model, data = observed_so_far),
    report_triangle = (model = tri_model,
        data = define_y_t(tri_obs, reported_triangle, eventual)),
    complete = (model = naive_model, data = eventual))

fits = map(specs) do spec
    post = as_turing_model(spec.model, spec.data, n)
    chain = sample(post, NUTS(1000, 0.95; adtype = adt), MCMCThreads(), 250, 2;
        progress = false)
    (; post, chain)
end

naive_post, naive_chain = fits.naive
rt_post, rt_chain = fits.right_truncate
tri_post, tri_chain = fits.report_triangle
complete_post, complete_chain = fits.complete
┌ Info: Found initial step size
└ ϵ = 0.00625
┌ Info: Found initial step size
└ ϵ = 0.0125
┌ Info: Found initial step size
└ ϵ = 0.025
┌ Info: Found initial step size
└ ϵ = 0.0125
┌ Info: Found initial step size
└ ϵ = 0.00625
┌ Info: Found initial step size
└ ϵ = 0.003125
┌ Info: Found initial step size
└ ϵ = 0.0125
┌ Info: Found initial step size
└ ϵ = 0.0125
┌ Warning: There were 1 divergent transitions. Consider reparameterising your model or using a smaller step size. For adaptive samplers such as NUTS and HMCDA, consider increasing `target_accept`.
└ @ Turing.Inference ~/.julia/packages/Turing/4sXd9/src/mcmc/hmc.jl:483
┌ Warning: There were 2 divergent transitions. Consider reparameterising your model or using a smaller step size. For adaptive samplers such as NUTS and HMCDA, consider increasing `target_accept`.
└ @ Turing.Inference ~/.julia/packages/Turing/4sXd9/src/mcmc/hmc.jl:483
┌ Warning: There were 3 divergent transitions. Consider reparameterising your model or using a smaller step size. For adaptive samplers such as NUTS and HMCDA, consider increasing `target_accept`.
└ @ Turing.Inference ~/.julia/packages/Turing/4sXd9/src/mcmc/hmc.jl:483Recent Rt
generated_observables. Averaging it over the most recent window shows the bias and its removal. Right-truncation biases the naive recent
using Statistics

function recent_Rt(post, chain; window = 7)
    gens = vec(generated_observables(post, nothing, chain).generated)
    Rt_mean = mean(exp.(g.Z_t) for g in gens)
    round(mean(Rt_mean[(end - window + 1):end]), digits = 2)
end

map(fit -> recent_Rt(fit.post, fit.chain), fits)
(naive = 0.3, right_truncate = 0.9, report_triangle = 0.88, complete = 0.91)Posterior prediction, nowcast, and Rt
Three views of the fits share the reference-day axis with the recent window shaded. The RightTruncate model's posterior-predictive observed-so-far, recovered with predict on the same model with the observations set to missing, against the data it was fit to.
ts = 1:n
Rt_complete = gen_bands(complete_post, complete_chain, g -> exp.(g.Z_t))
Rt_naive = gen_bands(naive_post, naive_chain, g -> exp.(g.Z_t))
Rt_rt = gen_bands(rt_post, rt_chain, g -> exp.(g.Z_t))
Rt_tri = gen_bands(tri_post, tri_chain, g -> exp.(g.Z_t))

now_rt = gen_bands(rt_post, rt_chain, g -> g.I_t)
now_tri = gen_bands(tri_post, tri_chain, g -> g.I_t)

rt_pred = predict(as_turing_model(rt_model, fill(missing, n), n), rt_chain)
yt = predictive_bands(rt_pred, n)

fig = Figure(; size = (780, 820))
ax1 = Axis(fig[1, 1]; ylabel = "Reproduction number Rₜ")
vspan!(ax1, n - 6, n; color = (:grey, 0.15))
ci_ribbon!(ax1, ts, Rt_complete; color = :black, label = "complete (reference)")
ci_ribbon!(ax1, ts, Rt_naive; color = :crimson, label = "naive")
ci_ribbon!(ax1, ts, Rt_rt; color = :seagreen, label = "right-truncate")
ci_ribbon!(ax1, ts, Rt_tri; color = :steelblue, label = "report-triangle")
hlines!(ax1, [1.0]; color = :grey, linestyle = :dash)
axislegend(ax1; position = :lb, nbanks = 2)

ax2 = Axis(fig[2, 1]; ylabel = "Eventual cases (nowcast)")
vspan!(ax2, n - 6, n; color = (:grey, 0.15))
ci_ribbon!(ax2, ts, now_rt; color = :seagreen, label = "right-truncate")
ci_ribbon!(ax2, ts, now_tri; color = :steelblue, label = "report-triangle")
lines!(ax2, ts, Float64.(eventual); color = :black, linewidth = 2,
    label = "true eventual")
scatter!(ax2, ts, observed_so_far; color = :grey, markersize = 6,
    label = "observed so far")
axislegend(ax2; position = :lt)

ax3 = Axis(fig[3, 1]; xlabel = "Reference day", ylabel = "Observed-so-far")
vspan!(ax3, n - 6, n; color = (:grey, 0.15))
ci_ribbon!(ax3, ts, yt; color = :teal, label = "posterior predictive")
scatter!(ax3, ts, observed_so_far; color = :black, markersize = 6,
    label = "observed")
axislegend(ax3; position = :lt)
fig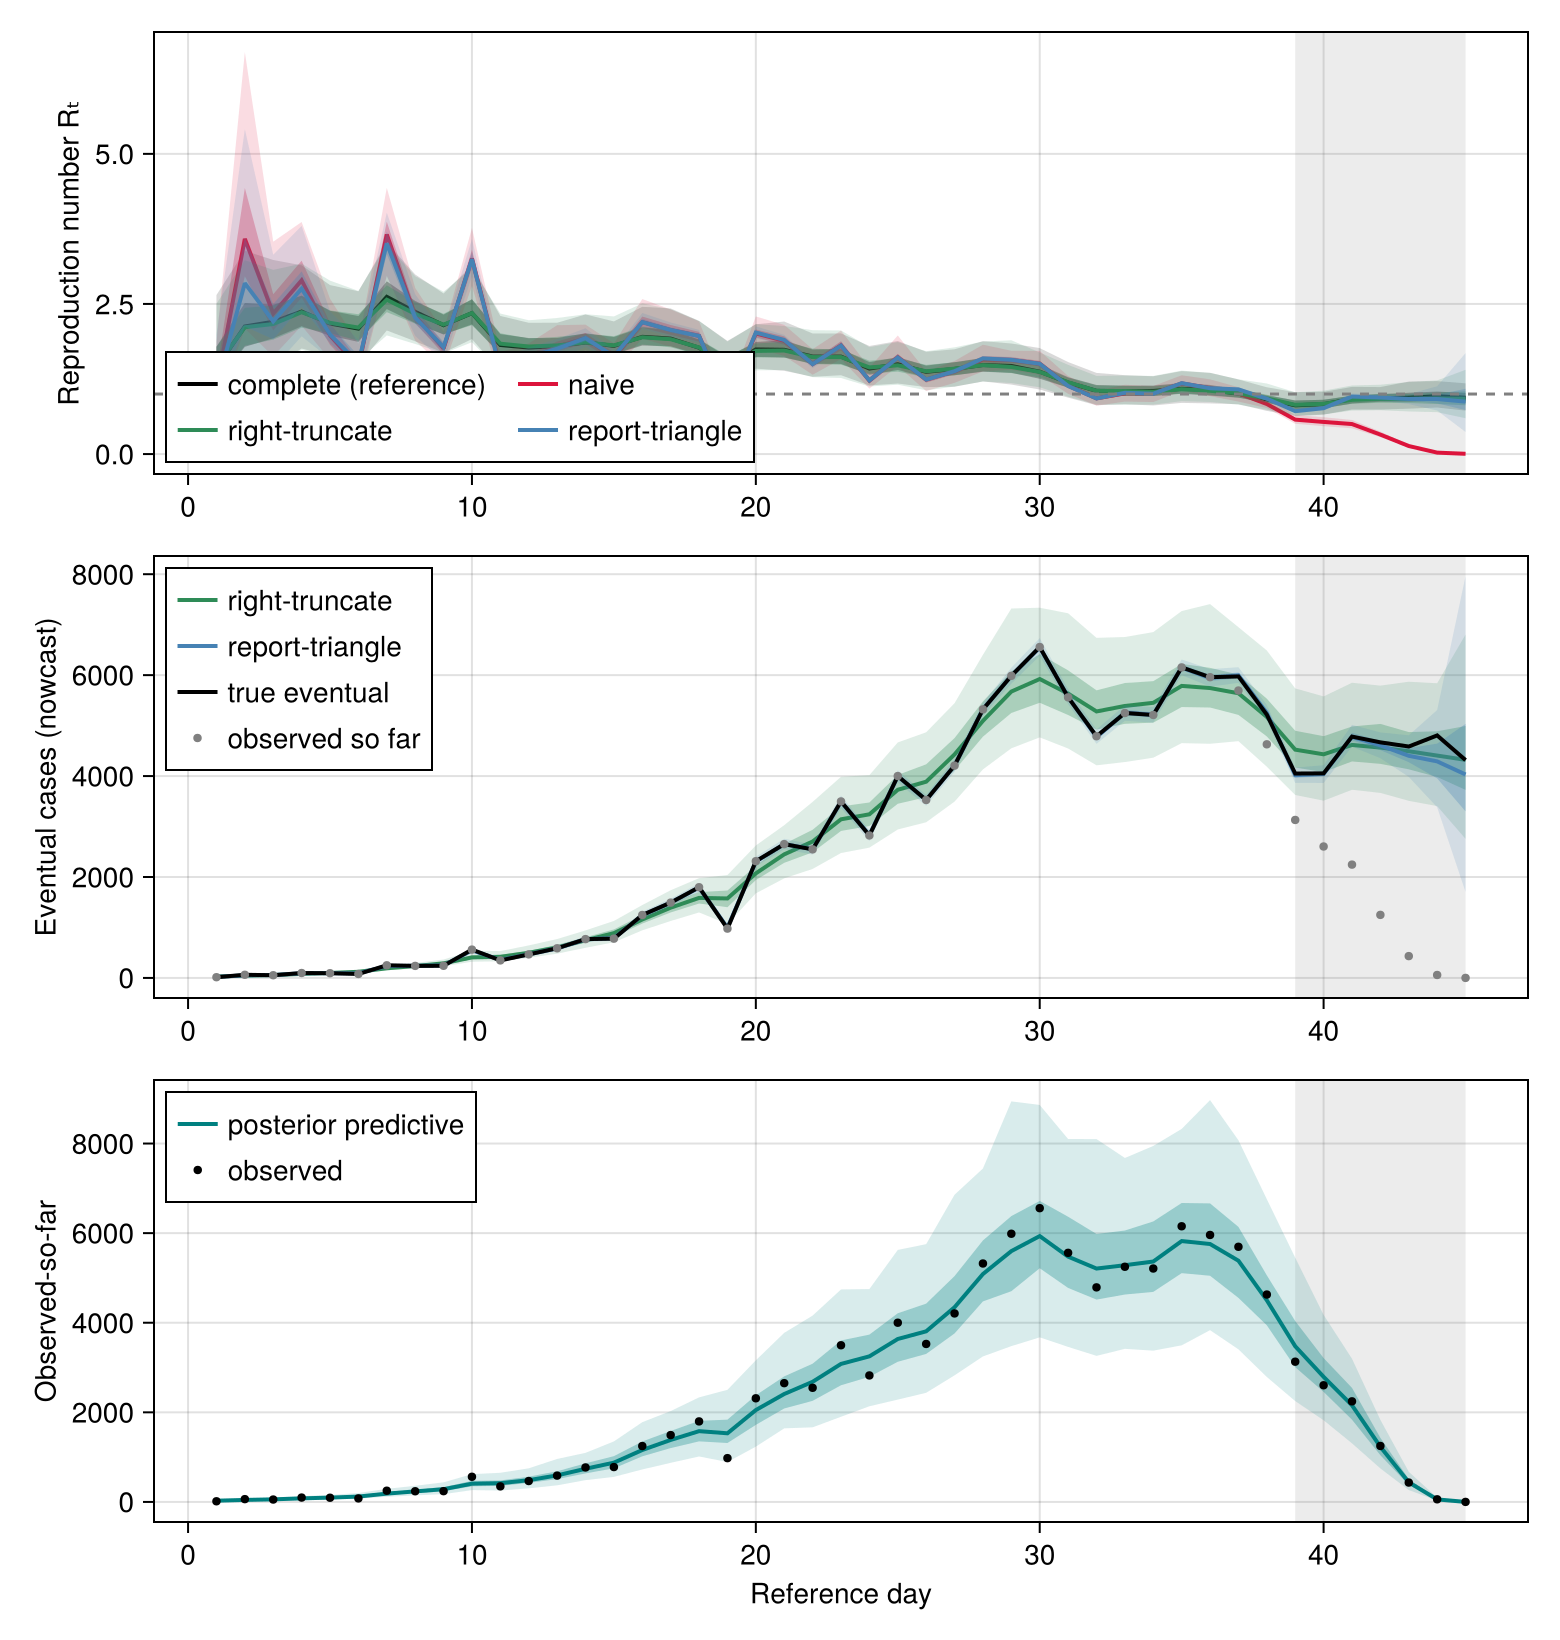
In the shaded recent window the naive RightTruncate fit reproduces the observed-so-far series it saw.
Shared parameters
Neither correction touches the renewal process, so both recover the same shared parameters, the autoregressive damping damp[1]), the innovation scale std), the observation overdispersion (cluster_factor) and the initial infections (init_incidence).
using MCMCChains
summarystats(tri_chain)╭─FlexiSummary (9 statistics) ─────────────────────────────────────────────────╮
│ iter collapsed │
│ chain collapsed │
│ ↓ stat = [mean, std, mcse, ess_bulk, ess_tail, rhat, q5, q50, q95] │
│ │
│ Parameters (50) ── AbstractPPL.VarName │
│ Float64 init[1], damp, ρ, std, ϵ_t[1], ϵ_t[2], ϵ_t[3], ϵ_t[4], ϵ_t[5], │
│ ϵ_t[6], ϵ_t[7], ϵ_t[8], ϵ_t[9], ϵ_t[10], ϵ_t[11], ϵ_t[12], │
│ ϵ_t[13], ϵ_t[14], ϵ_t[15], ϵ_t[16], ϵ_t[17], ϵ_t[18], ϵ_t[19], │
│ ϵ_t[20], ϵ_t[21], ϵ_t[22], ϵ_t[23], ϵ_t[24], ϵ_t[25], ϵ_t[26], │
│ ϵ_t[27], ϵ_t[28], ϵ_t[29], ϵ_t[30], ϵ_t[31], ϵ_t[32], ϵ_t[33], │
│ ϵ_t[34], ϵ_t[35], ϵ_t[36], ϵ_t[37], ϵ_t[38], ϵ_t[39], ϵ_t[40], │
│ ϵ_t[41], ϵ_t[42], ϵ_t[43], ϵ_t[44], init_incidence, │
│ cluster_factor │
│ │
│ Extras (14) │
│ Float64 n_steps, is_accept, acceptance_rate, log_density, │
│ hamiltonian_energy, hamiltonian_energy_error, │
│ max_hamiltonian_energy_error, tree_depth, numerical_error, │
│ step_size, nom_step_size, logprior, loglikelihood, logjoint │
│ │
│ Summary │
│ param mean std mcse ess_bulk ess_tail rhat … │
│ init[1] 0.1086 0.2931 0.0400 53.9299 110.1585 1.0092 … │
│ damp 0.7846 0.0452 0.0136 11.9950 24.3737 1.1169 … │
│ ρ 0.7846 0.0452 0.0136 11.9950 24.3737 1.1169 … │
│ std 0.3144 0.0293 0.0080 13.5512 51.3326 1.0402 … │
│ ϵ_t[1] 3.0080 0.7570 0.1182 40.5647 75.7999 0.9998 … │
│ ϵ_t[2] -0.0795 0.6563 0.1023 39.6271 98.0348 1.0412 … │
│ ϵ_t[3] 1.2543 0.4957 0.0583 71.7512 121.9873 1.0076 … │
│ ϵ_t[4] -0.3354 0.4293 0.0661 42.4113 92.7750 1.0198 … │
│ ϵ_t[5] -0.4061 0.4375 0.0531 66.1227 179.1219 1.0068 … │
│ ϵ_t[6] 2.9800 0.4335 0.0714 37.4075 154.6013 1.0334 … │
│ ϵ_t[7] -0.5158 0.3969 0.0527 53.5915 73.9288 1.0119 … │
│ ϵ_t[8] -0.2303 0.3081 0.0333 85.6160 81.0039 1.0241 … │
│ ϵ_t[9] 2.3312 0.3164 0.0911 12.4592 168.7149 1.0854 … │
│ ϵ_t[10] -1.8666 0.3157 0.0555 33.8225 49.1867 1.0071 … │
│ ϵ_t[11] 0.6802 0.2158 0.0285 59.0324 139.4831 1.0463 … │
│ ϵ_t[12] 0.5810 0.2226 0.0303 55.9988 117.9778 1.0044 … │
│ ϵ_t[13] 0.7059 0.2330 0.0370 45.5873 40.6738 1.0369 … │
│ ϵ_t[14] -0.1081 0.1874 0.0291 43.4217 90.8820 1.0218 … │
│ ϵ_t[15] 1.3177 0.1887 0.0386 24.7272 93.7628 1.0656 … │
│ ϵ_t[16] 0.3412 0.1891 0.0444 17.8535 59.8187 1.0962 … │
│ ϵ_t[17] 0.3383 0.1630 0.0235 49.9377 92.1203 1.0421 … │
│ ϵ_t[18] -2.1157 0.2543 0.0638 16.1399 57.0774 1.0260 … │
│ ϵ_t[19] 2.5832 0.2597 0.0648 16.2388 117.1820 1.0219 … │
│ ϵ_t[20] 0.2857 0.1482 0.0313 22.4290 36.4198 1.0774 … │
│ ϵ_t[21] -0.3213 0.1449 0.0318 22.8188 36.0683 1.0328 … │
│ ϵ_t[22] 0.8797 0.1225 0.0500 6.1554 108.9433 1.1397 … │
│ ϵ_t[23] -0.8323 0.1471 0.0322 21.3275 50.6233 1.0371 … │
│ ϵ_t[24] 1.0097 0.1270 0.0535 5.6866 50.5214 1.1513 … │
│ ϵ_t[25] -0.5082 0.1214 0.0261 23.5860 29.8464 1.0087 … │
│ ϵ_t[26] 0.4902 0.0865 0.0153 32.6622 143.3287 1.0360 … │
│ ϵ_t[27] 0.6835 0.1032 0.0341 9.7906 74.7083 1.1108 … │
│ ϵ_t[28] 0.2746 0.0906 0.0199 21.0484 143.9406 1.0755 … │
│ ϵ_t[29] 0.1741 0.0953 0.0187 26.2251 58.4054 1.0562 … │
│ ϵ_t[30] -0.6275 0.1059 0.0222 24.7746 50.2483 1.0118 … │
│ ϵ_t[31] -0.5618 0.0915 0.0185 23.9872 137.6375 1.0026 … │
│ ϵ_t[32] 0.2610 0.0703 0.0107 43.4444 100.4579 1.0039 … │
│ ϵ_t[33] -0.0369 0.0681 0.0077 79.8381 124.1532 1.0105 … │
│ ϵ_t[34] 0.5212 0.0783 0.0140 31.6137 49.5578 1.0135 … │
│ ϵ_t[35] -0.1254 0.0733 0.0141 32.4372 47.5360 1.0347 … │
│ ϵ_t[36] 0.0078 0.0682 0.0078 79.3643 97.0484 1.0183 … │
│ ϵ_t[37] -0.4463 0.0831 0.0167 26.0215 53.1560 1.0043 … │
│ ϵ_t[38] -0.8763 0.1077 0.0178 36.7674 110.0285 1.0195 … │
│ ϵ_t[39] -0.0174 0.1015 0.0256 16.9070 88.2224 1.1023 … │
│ ϵ_t[40] 0.5450 0.1246 0.0277 20.8237 100.1520 1.0098 … │
│ ϵ_t[41] -0.0911 0.1274 0.0164 63.4532 70.1062 1.0254 … │
│ ϵ_t[42] -0.1293 0.1776 0.0225 63.6180 124.5383 1.0020 … │
│ ϵ_t[43] -0.0738 0.4111 0.0452 83.1611 205.1149 1.0009 … │
│ ϵ_t[44] -0.1845 1.0468 0.1056 106.7008 79.2638 1.0018 … │
│ init_incide… 2.9568 0.2548 0.0405 40.3687 75.0883 1.0075 … │
│ cluster_fac… 0.0102 0.0061 0.0005 125.1904 79.0610 0.9996 … │
╰──────────────────────────────────────────────────────────────────────────────╯Prior versus posterior
Sampling the reporting-triangle model with Prior and overlaying it on the posterior with PairPlots.jl confirms the joint correction still identifies the shared parameters from the thinned triangle.
using PairPlots

prior_chain = sample(tri_post, Prior(), 1000; progress = false)
pp_keys = [@varname(damp), @varname(std),
    @varname(cluster_factor), @varname(init_incidence)]
pairplot(
    PairPlots.Series(tri_chain[pp_keys]; label = "posterior"),
    PairPlots.Series(prior_chain[pp_keys]; label = "prior"))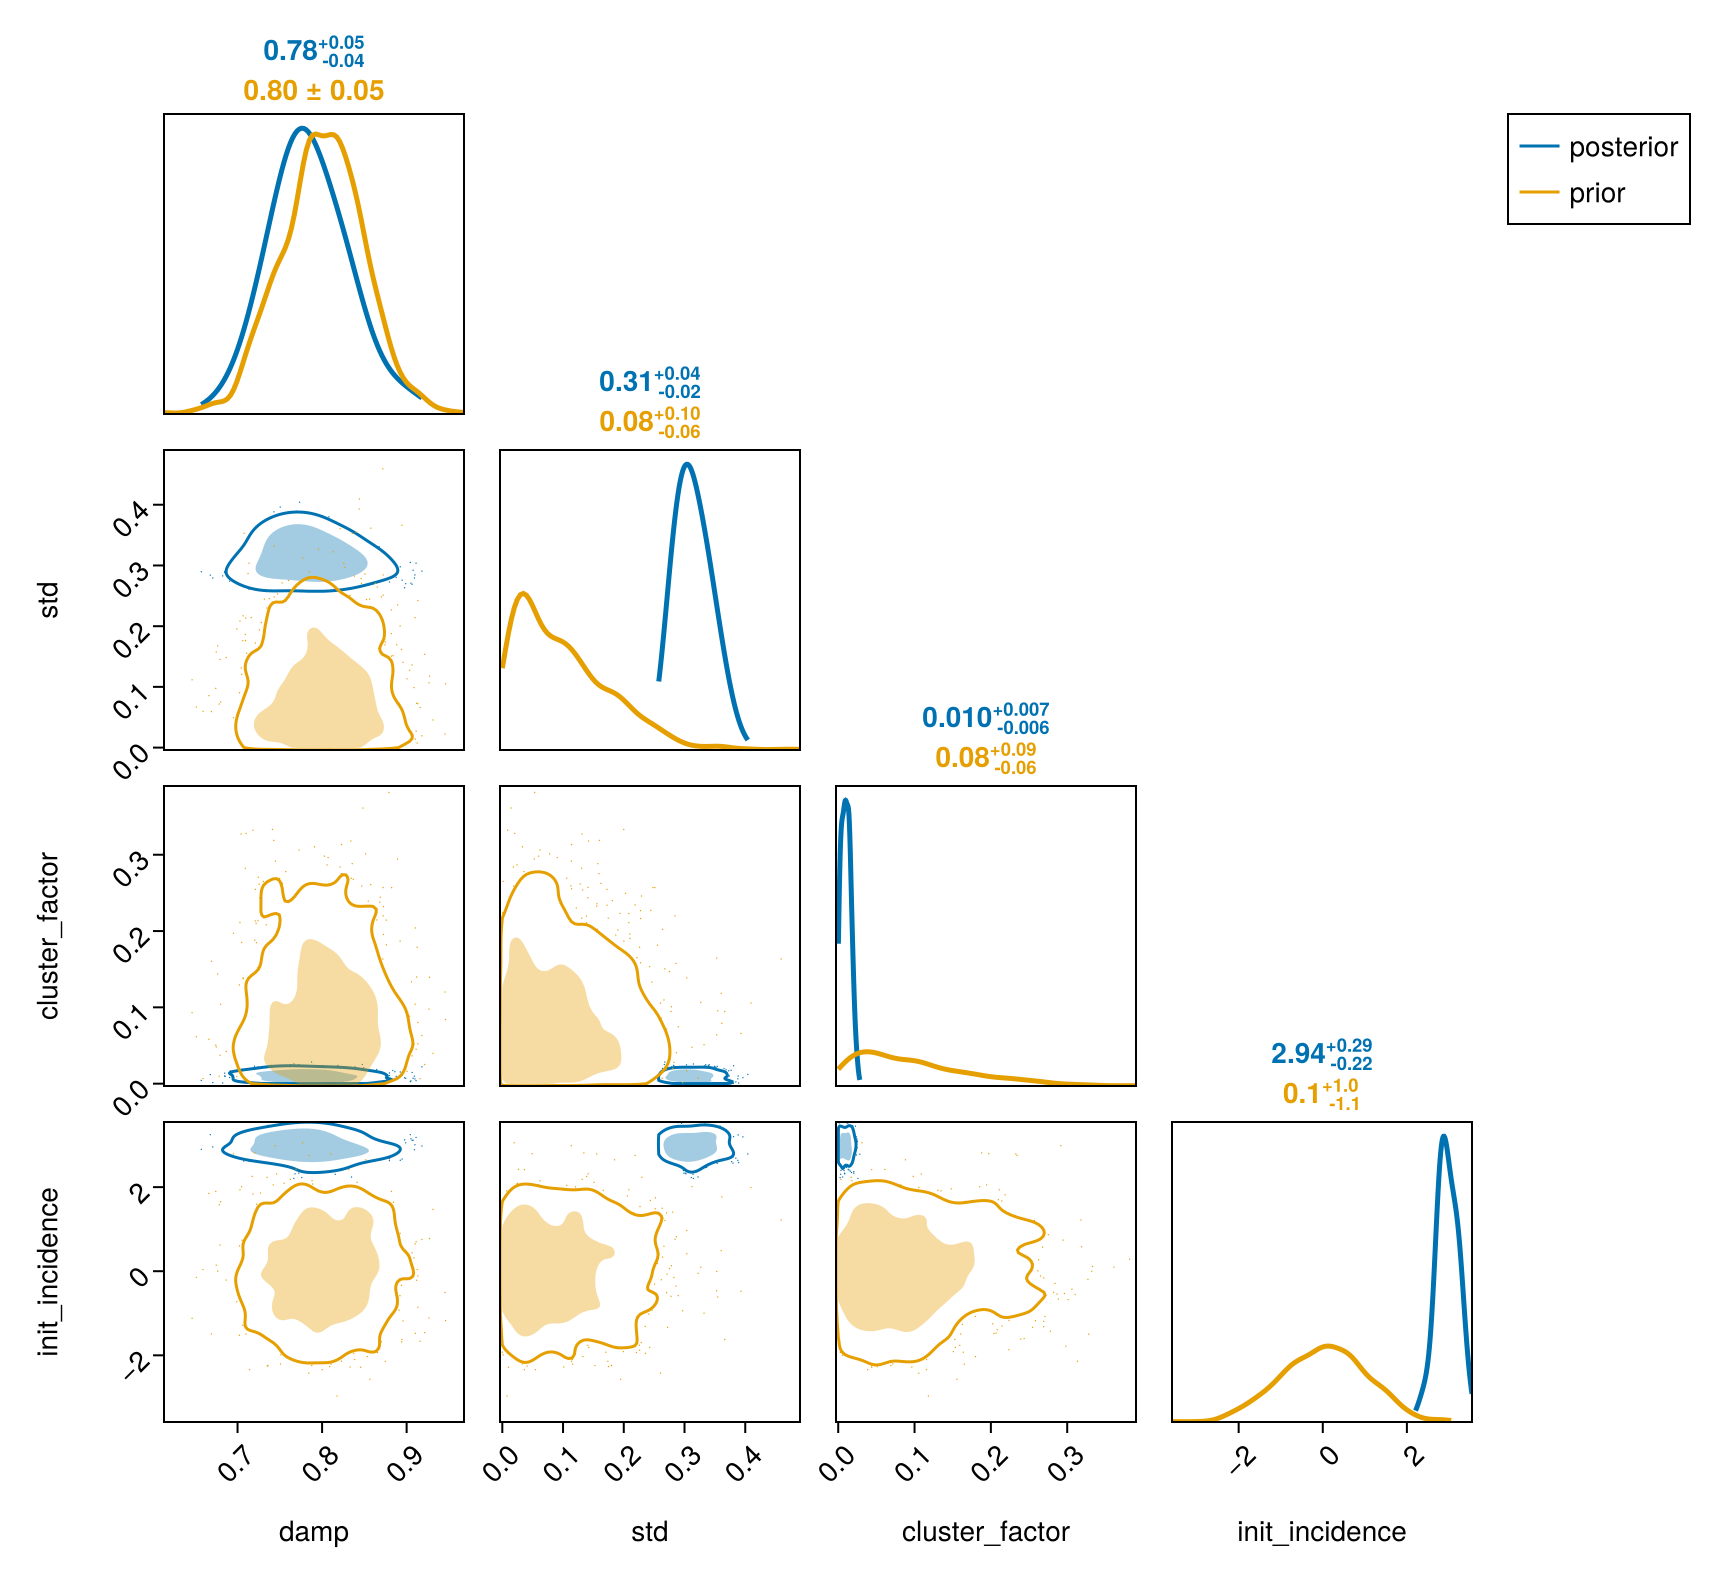
References
- S. Abbott, J. Hellewell, R. N. Thompson, K. Sherratt, H. P. Gibbs, N. I. Bosse, J. D. Munday, S. Meakin, E. L. Doughty, J. Y. Chun and others. Estimating the time-varying reproduction number of SARS-CoV-2 using national and subnational case counts. Wellcome Open Research 5, 112 (2020).